i-Vision Group, Tsinghua University

Ziyang Cheng

Ph.D. Student in Electronic Information at Tsinghua University

I am a first-year Ph.D. student in the Department of Automation at Tsinghua University, advised by Prof. Jiwen Lu.

Before that, I completed my undergraduate studies at Tsinghua University (2022–2026), earning bachelor's degrees in Mathematics and Physics & Mechanical Engineering.

In 2025, I worked as a research intern at the University of Illinois Urbana-Champaign (UIUC) with Prof. Yuxiong Wang.

I work on robotics and machine learning. My current research focuses on:

  1. Whole-Body Control for Legged Robots, studying coordinated whole-body behaviors for loco-manipulation.
  2. Humanoid Teleoperation, developing intuitive teleoperation systems that transfer human intent to humanoid robots.
  3. Safe and Robust Robotics, addressing both physical and semantic safety for robots operating in complex environments.
Ziyang Cheng at Tsinghua University

Updates

News

  • Major update to GigaBrain-WBC-0.5, including new ablation studies.

  • CMP and F2F-AP were accepted to CoRL 2026, with CMP selected for Spotlight.

  • Released the technical report for GigaBrain-WBC-0.5.

Selected work

Publications

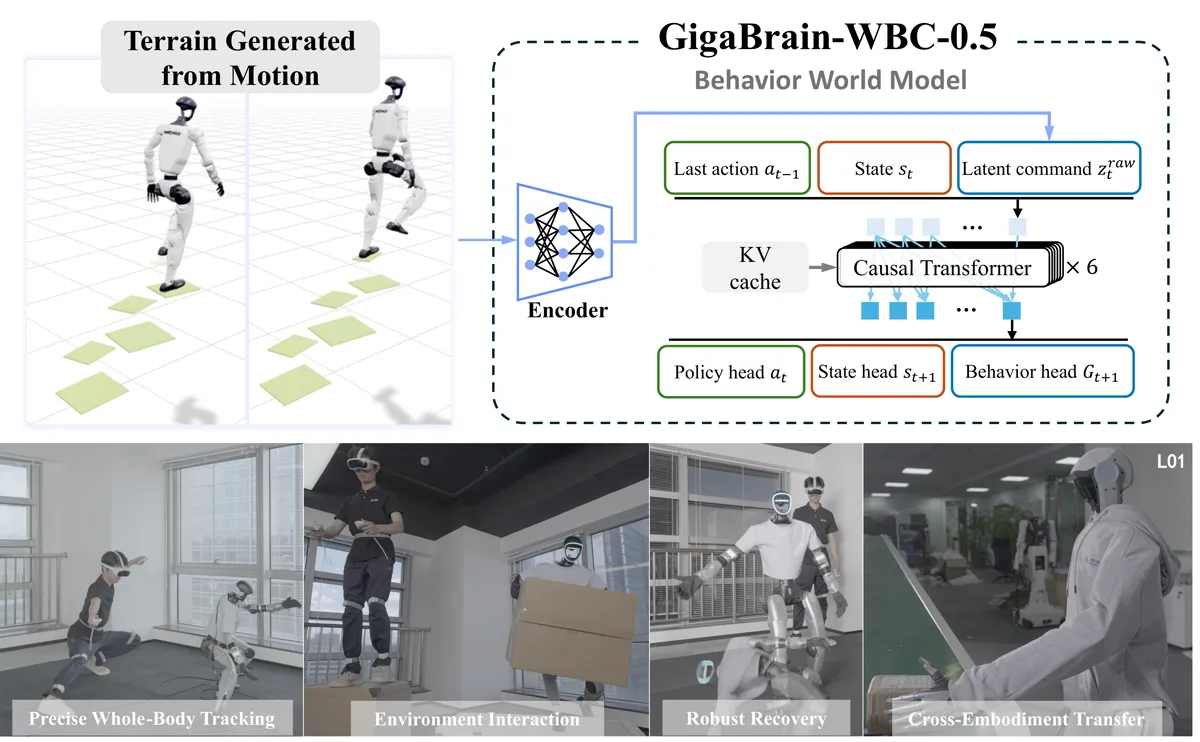
Overview of the GigaBrain-WBC behavior world model and robot demonstrations
2026Technical Report

GigaBrain-WBC-0.5: A Behavior World Model for Robust Humanoid Whole-Body Tracking with Environment Interaction

Ziyang Cheng, Tianshu Tang, Jinxin Lan, Xinze Chen, Yuhan Gong, Zhichao Liu, Changzhong Wu, Yahao Mao, Zongyan Deng, Mingxuan Ma, Huasen Xi, Yilong Liu, Yutong Wu, Xiaofeng Wang, Borui Zhang, Bingyao Yu, Yang Wang, Yun Ye, Guan Huang, Xiaojie Jin, Zheng Zhu#, Jiwen Lu#

arXiv preprint arXiv:2608.18234

We present GigaBrain-WBC-0.5, a behavior world model for humanoid whole-body control. It predicts actions, states, and behavior commands to support environment interaction, reject implausible commands, recover from falls, and withstand disturbances.
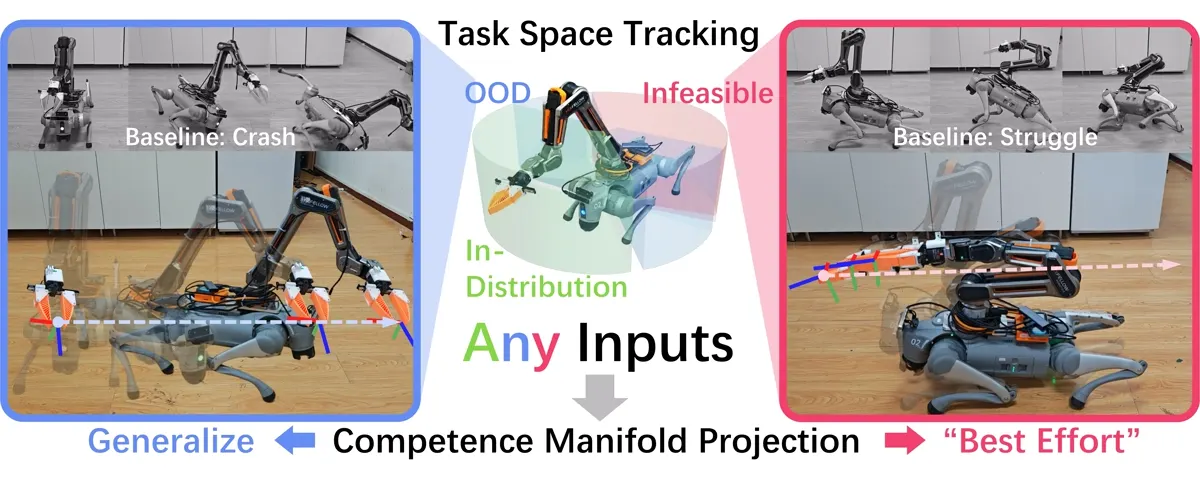
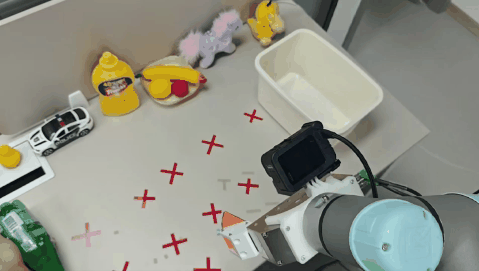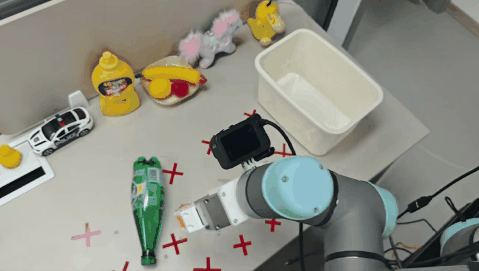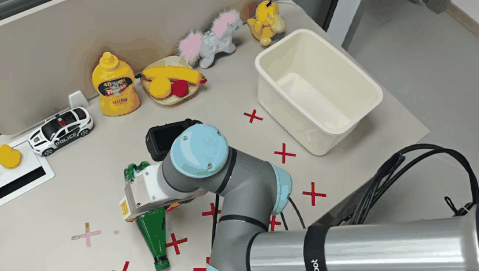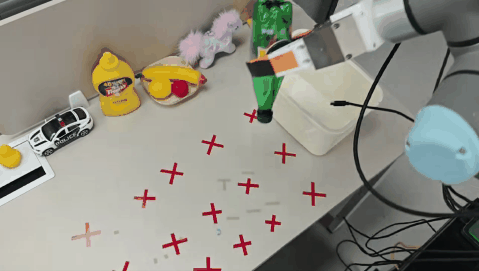
Robot demonstrations and competence manifold projection overview for CMP
2026CoRL

CMP: Robust Whole-Body Tracking for Loco-Manipulation via Competence Manifold Projection

Ziyang Cheng, Haoyu Wei, Hang Yin, Xiuwei Xu, Bingyao Yu, Jie Zhou, Jiwen Lu#

Conference on Robot Learning (CoRL), 2026 — Spotlight

We propose CMP, a competence manifold projection method for robust whole-body tracking in loco-manipulation. It projects unsafe or out-of-distribution commands onto learned competence boundaries, improving survival by up to tenfold with limited tracking degradation.

F2F-AP real-time dynamic manipulation demonstrations
2026CoRL

F2F-AP: Flow-to-Future Asynchronous Policy for Real-time Dynamic Manipulation

Haoyu Wei, Xiuwei Xu†, Ziyang Cheng, Hang Yin, Angyuan Ma, Bingyao Yu, Jie Zhou, Jiwen Lu#

Conference on Robot Learning (CoRL), 2026

We propose F2F-AP, a flow-to-future asynchronous policy for real-time dynamic manipulation. It predicts object flow to synthesize future observations and aligns visual features with future states, allowing policies to compensate for latency and interact with moving objects.

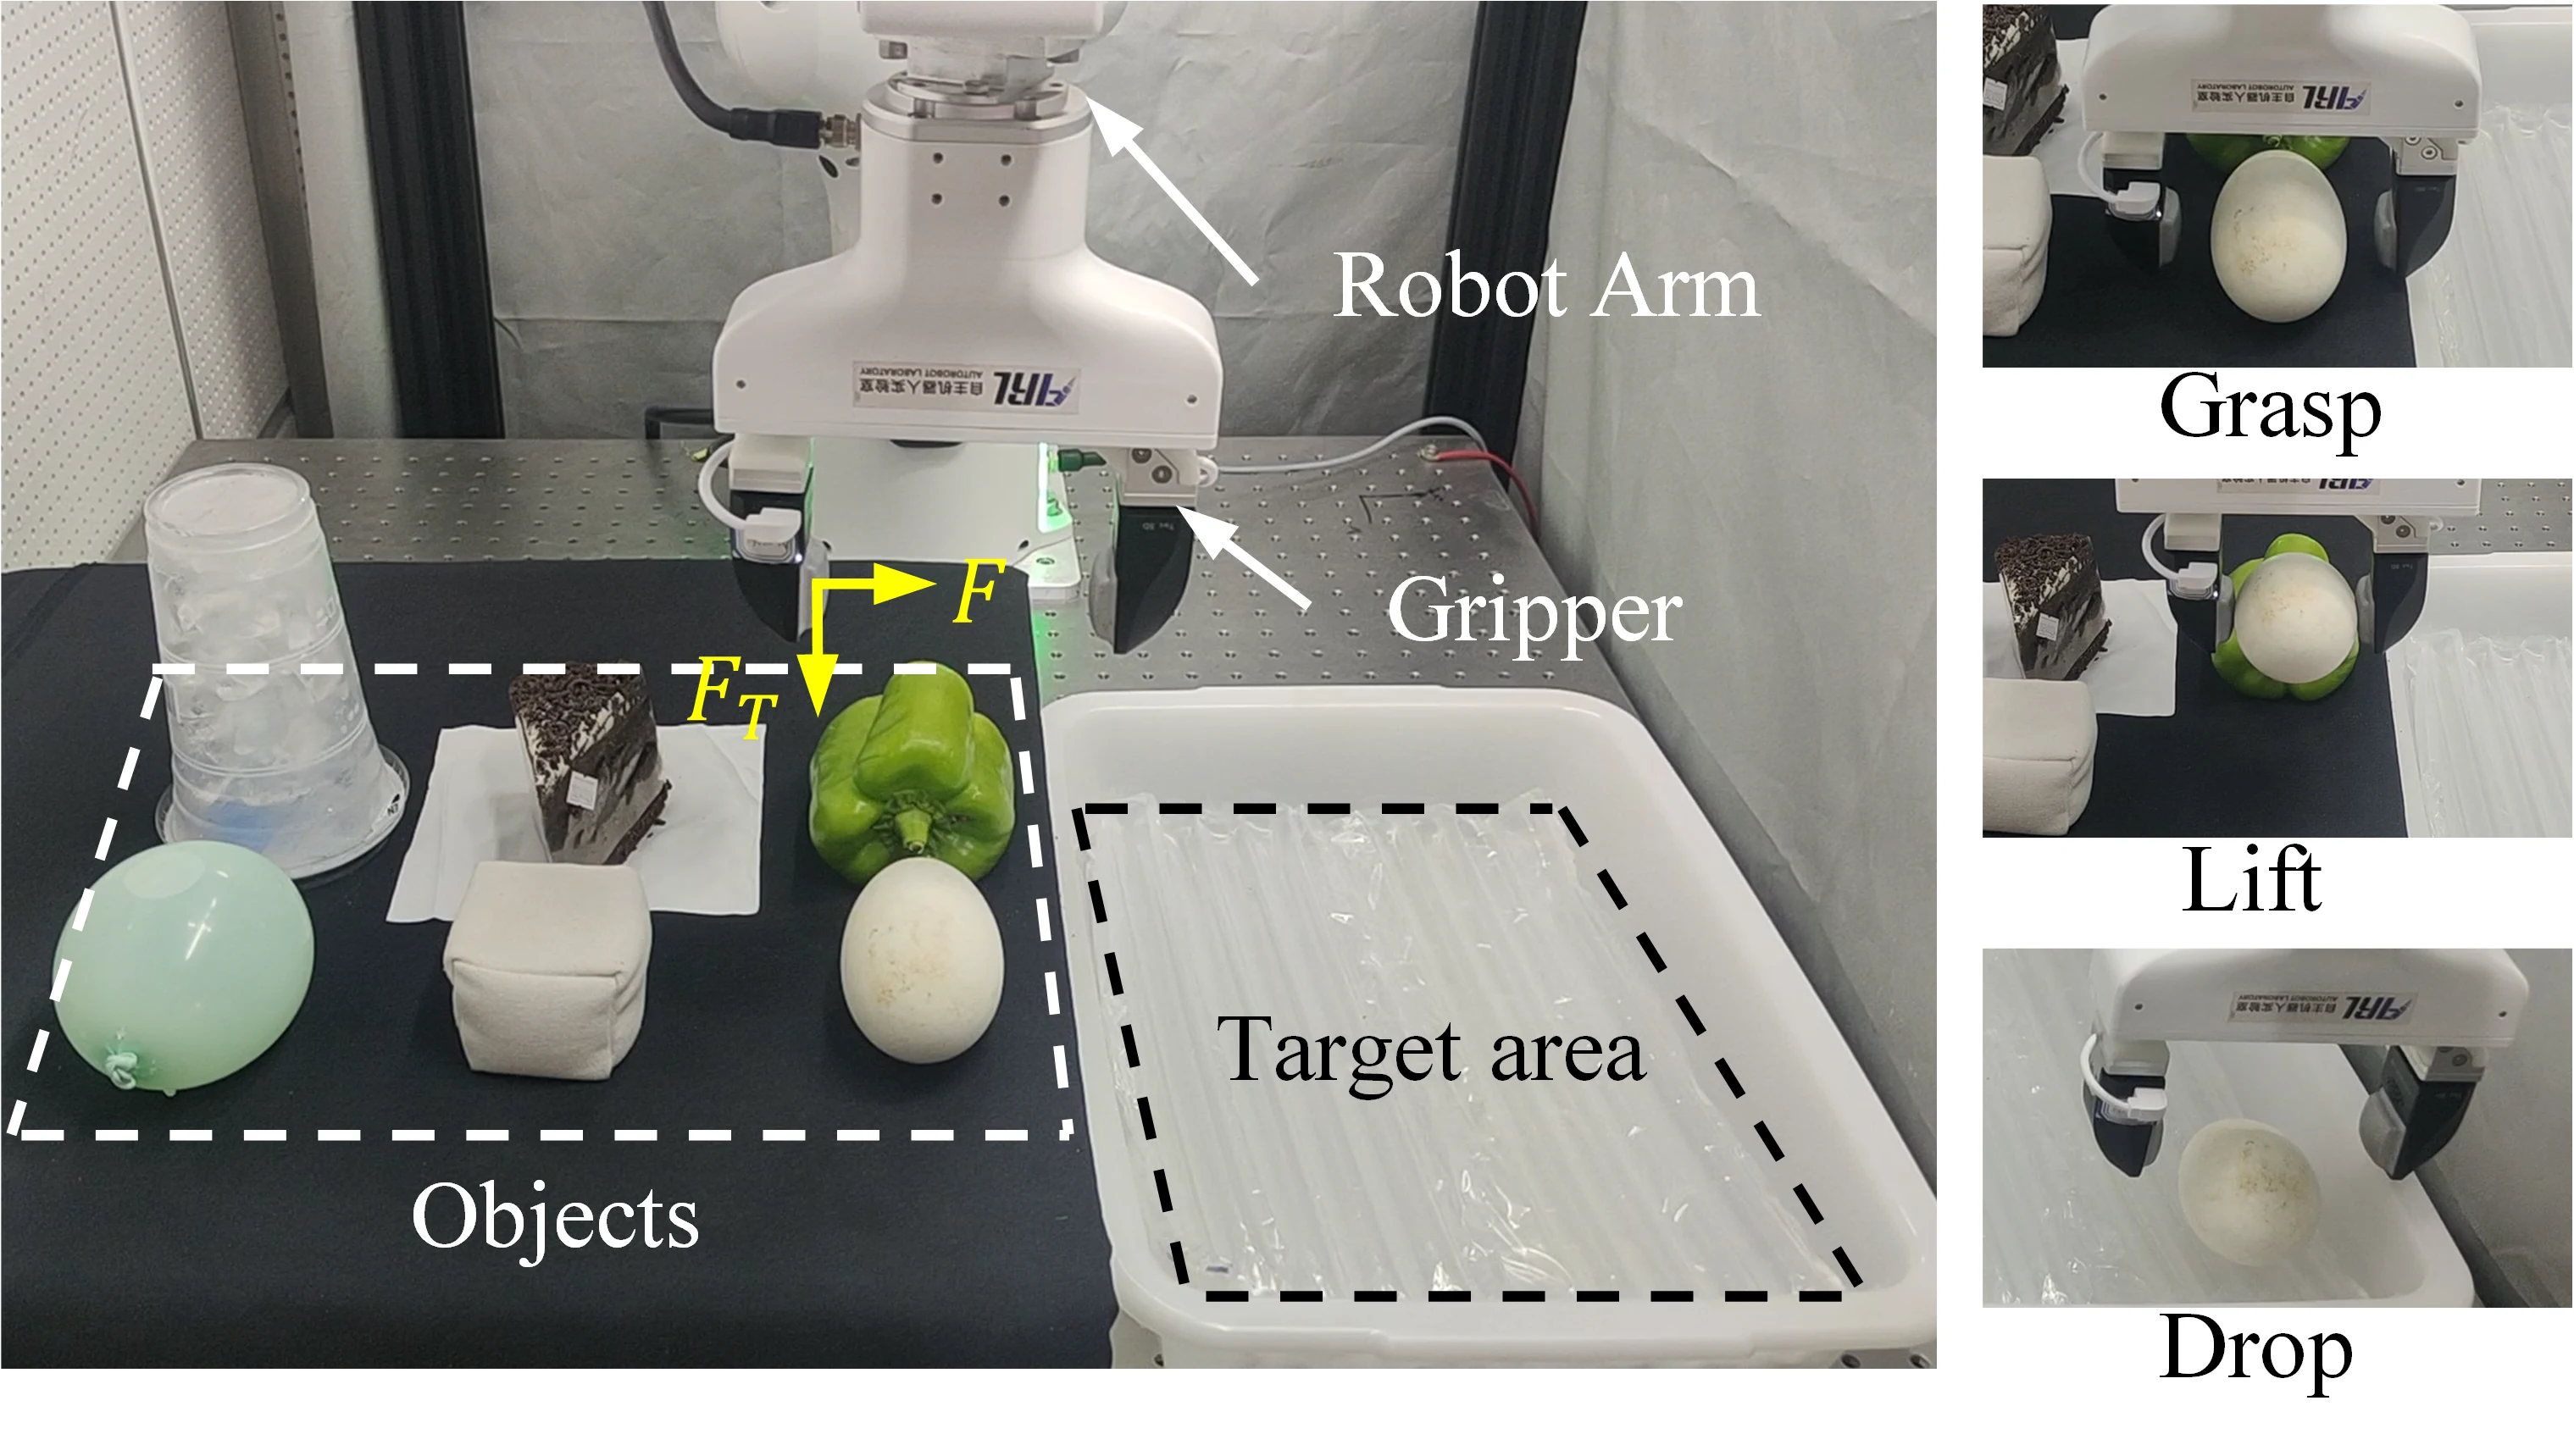
Adaptive grasping force tracking control diagram and experimental platform
2025IEEE T-ASE

An Adaptive Grasping Force Tracking Strategy for Nonlinear and Time-Varying Object Behaviors

Ziyang Cheng, Xiangyu Tian, Ruomin Sui, Tiemin Li, Yao Jiang#

IEEE Transactions on Automation Science and Engineering, vol. 22, pp. 17063–17076

We introduce generalized stiffness for nonlinear, time-varying grasp systems and estimate it online with an LSTM. The resulting adaptive PI strategy tracks grasp force accurately across unknown object behaviors, improving robotic grasping in unstructured environments.

* Equal contribution, † Project leader, # Corresponding author.

Recognition

Grants, Honors & Awards

Honors & Grants

  1. 2024National Scholarship, China
  2. 2025Undergraduate Qiyan Research Program, Beijing Natural Science Foundation
  3. 2024Scientific and Technological Innovation Excellence Scholarship, Tsinghua University
  4. 2023Comprehensive Excellence Scholarship, Tsinghua University
  5. 18thSelected Participant, Spark Scientific and Technological Innovation Fellowship, Tsinghua University

Competitions

  1. First Prize39th National Undergraduate Physics Competition
  2. First Prize2024 Student Research Training Program Outstanding Project
  3. 3rd Place & Second Prize42nd Tsinghua University Challenge Cup Competition (First Author)

Academic Service

Invited reviewer for IEEE T-ASE; conference reviewer for CoRL.

Get in touch

Let's talk about robots!

zycheng1226@gmail.com